Monday, July 19, 2010

Notes from 07/ 14/10

Here are some notes I took on the past Wednesday.
Professor Sullivan continued his topic about "the fundamental group". To construct a fundamental group using the universal covering space, we first need following definitions.
[Definition] A metric space is an ordered pair (M,d) where M is a set and d is a metric on M, that is a function

d: M*M -> R

such that for any x, y, z in M
1. non-negativity: d(x,y) >= 0
2. identity of indiscernibles: d(x,y) =0 iff x = y
3. symmetry: d(x,y) = d (y,x)
4. triangle inequality: d(x,z) <= d(x,y) + d(y,z)


[Definition] Given a metric space (X, d), a subset U is called open iff for any element u in U, there exists a set B(u,r) = {vd(u,v)<=r}.


Now the metric space X is also a topological space.


We will assume that X is locally simply connected. Then we can construct a universal covering space and a covering map to study some important consequence of the fundamental group.
Step 1: Let X be a topological space and choose a base point x in X.
Step 2: For each point x' in X, consider all the continuous paths (i.e a continuous map from [0,1]to X) from the base point x to x'. We say that two such paths are equivalent if they can be deformed to one another without moving the start and end points and without breaking. These two paths are the same "rout".


[Definition:] The set of all such routs is the universal covering space X~. The covering map is the map from X~ to X that maps any rout, from x to x', to x'.


[Definition:] If X is a metric space with metric d, then the length the curve g: [a,b] -> X is
length(g)= sup{These sumnation from i=0 to n-1 of d(g(ti),g(t(i+1)): n is a natural number and a=t0 < t1<... < tn=b}.


[Definition:] A metric space is a length metric space if the intrinsic metric (i.e. the infimum of the length of all paths from one point to the other) agrees with the original metric of the space.


Unsurprisingly, the shortest paths are constant paths and they are nowhere differentiable. Also, since we mentioned last time, the covering map is a local isometry. An isometry is a distance-preserving map between two metric spaces so it is easy to understand that the covering map preserves the path lengths.


Next, we came to a theorem which allows us to do much with the covering spaces.


[Theorem (Homotopy Lifting):] Suppose p: Z -> X is a covering map for a space X. Let f : I^n -> X be a map from the unit n-cube to X, and F: I^ (n+1) -> X a homotopy of f to another map f' : I^n -> X. Suppose g : I^n -> Z is a map satisfying p* g =f. Then there exists a unique map L: I^(n+1) ->Z satisfying LI^n = g; p*L = F


It says that if z in Z is a point such that p(z)=x, and g is a path in X starting at x, then there is a unique path g' in Z starting at z such that p of g'=g. We say that a path in X has a unique lift to Z, once the starting point of the lift has been chosen.


[Definition:] The product of the two paths is called action.
More precisely, Let G be a topological group and X any topological set. If there is a continuous function f: G*X -> X, where G*X is given the product topology such that f(1,x) = x as well as f(g1g2,x) = f(g1, f(g2,x)), then the function is called the action of G on X.


[Theorem:]1. The fiber over the base point is a group.
2. This group Gamma_x acts on every fiber Gamma_x'.
Gamma_x * Gamma_x' -> Gamma_x'


3
. The action is by left translation in the Gamma_x.
4. The action on each Gamma_x' is without fixed points unless acting with the identity.


After the lecture given by Professor Sullivan, the undergrad reported their progress during the week.


After having a good understanding of the problem, Keren started calculating the geometric length of a given geodesic in a given hyperbolic surface and study its distribution. She explained that in the upper-half of the Poincare disk model, in order to compute the geometric length, we needed to find out the eigenvalues of the transform matrices and then compute its trace. Actually she is now trying very hard to get these eigenvalues.


Ren's project is about exploring surface transformation. Start with three holes in the plane with a circle enclosing the right two. Then switch the points: left over the middle and right over the middle and keep doing those two steps. The numbers of the times that the loops pass under each hole are always the Fibonacci numbers. The sequence of lengths of the iterates of the curve grows exponentially with rate the Golden ratio.


Also, one of the properties of this surface transformation can be represented by the pattern of the curve words which are composed of A,a,B,b,C,c. The pattern is the following: In all the even steps, we change all the A's (a's) to ABa's (Aba's) and change all the B's (b's) to A's (a's). In all the odd steps, we change all the B's (b's) to C's (c's) and change all the C's (c's) to cBC's (cbC's).


Anand continued his project on finding the minimum intersections of all the cyclic reduced words of a given lengths with another fixed surface word. In the beginning of this project, Anand started with some simple surfaces. Next, he was collecting data under each condition step by step and tried to modify his problem with the help of computer program.


Tuesday, July 13, 2010

Notes From 07/07/10

The meeting is mainly about undergrad progress reports.


Robert continued his project on configurations on hyperbolic surfaces (a pair of pants) that are realizable as geodesics. He attempted to show that by adding one more round in the configuration to one of the legs, similar results exist regarding realizable configurations.


However, the sums of exterior and interior angles are insufficient to produce a contradiction on the configuration suspected to be unrealizable. By taking into account the areas of various shapes as well, and using the formula


-Area+Exterior Angles=2pi*Euler Characteristic


It may be possible to find a contradiction.


Jingyu formalized the relevant definitions and suggested an approach to her project about self-intersection and mutual-intersection of multiwords. She defined cyclic reduced words (abbreviated as c.r.w.), intersection of c.r.w. as the number of minimal self-intersection of a representative of the homotopy class described by c.r.w., multi-words as a list of c.r.w., as well as self- and mutual-intersection of multiwords similar to the definition of intersection of c.r.w. She was to find a representative of a multiword such that the sum of its self- and mutual intersection is minimum. She realized that it is attained when both the self- and mutual-intersection are minimum, according to some existing theorems, and proposed an algorithm to find the representative.


She defined bigon as a shape of two vertices and two arcs connected to the vertices. A proper bigon is a bigon that cannot be eliminated through surgery, and a bigon that is not proper is called an improper bigon. The related theorem then states that the total intersection is minimal when all improper bigons are eliminated through surgery. This theorem implies that minimal total intersection is attained when self- and mutual-intersection are both minimum. It then follows that for a give configuration, we can reduce bigons from the outmost to the inmost, and end up with the desired configuration.


Keren's project is about finding the distribution of geometric length of a geodesic for a certain combinatorial length in a given hyperbolic surface, and the range of the geometric length to combinatorial length ratio. A hyperbolic surface can be projected to a Poincare disk model or an upper half-plane. In the Ppincare model, a surface is represented by a surface word, and the combinatorial length of a geodesic is the number of letters in the word of the curve. In the upper half-plane model, the actual geometric length can be computed from the trace of the transform matrices.


In the upper half-plane model, the x-coordinates of an axis of transformation of a geodesic can be determined by the slopes of eigenvectors of that transform matrix, while the length of the axis be related to the trace of the matrix. For a certain word of a geodesic, its length has the following relationship with the multiplication of all transform matices (denoted by M):

cosh(l/2)=(1/2)Tr(M)

Therefore we can calculate the geometric length of any given geodesic and study its distribution.


Also, Dr. Sullivan has talked about universal covering space.

He started with the fact that two simply connected geodesically complete surfaces of constant curvature -1 are isometric. This is also true for zero and curvature +1. Simply connected means the surface can shrink to a point, and geodesically complete means a curve never leaves the surface. This fact can be proved by the theory of covering spaces.

A corollary of this fact suggests that for any connected surface of -1 curvature and "complete", then its universal covering space is isometric to the noneuclidian plane, and its covering symmetry group becomes a group of noneuclidian motions. This group is called the Poincare group or fundamental group.

For any topological space X (with tiny assumption that X is path connected with locally "unique" paths up to deformation), choose a point x in X as the base point, then all the ways of going to a point from the base point can be drawn as a stack of points above the space. If you slide a pint locally, there is a cononical bijection between the ways. Moving the base point along a closed path produces a permutation of the stack of of the base point. This is the original definition of the fundamental group by Poincare.

Group of transformations of universal covering space is given as follows:

Given (X,x), we construct (X',x') with a map Pi: (X',x')->(X,x). The group of continuous bijections to fixed points Gamma= Pi_1(X,x) such that X'/Gamma=X and X' is simply connected.

(BTW X' and x' should actually be X- and x-tilde, I cannot type it)

Tuesday, June 29, 2010

Notes from 06/23/10

The meeting started with undergraduate projects reports:

Anand's problem is that given a surface (the pair of pants or the punctured torus), find the minimum intersections of all the cyclic reduced words (which are composed of a, b, A, B, where A and B are the inverses of a and b respectively)of a given length with another fixed surface word (For example, Ab or aB). He started to run Chris's program of computing minimum intersections of a single word and tried to modify it for his problem.

Jingyu's project is similar. Given the fixed surface (the pair of pants or the punctured torus), she needs to study the maximal number of minimum crossings (including the self-intersections and mutual intersections) of a multi-word (which defined as a finite collection of cyclic reduced words whose combinatorial length add up to the total length of the multi-word).
Now she is trying to come up with a computer program to solve this problem.

Rob's problem is to study the realizations as geodesics of a give configuration in hyperbolic geometry. Now he is trying to show that if the given configuration wraps around one more time of one of the legs of the pair of pants, the configuration which passes the triple point is still not realizable as before. However, no obvious contradiction can be deduced from his classic argument (considering the sum of the interior angles of the front triangle and the sum of the exterior angles of the back hexagon and derive a contradiction).

The Agenda for the main discussion:
1.Construction of surfaces of constant negate curvature.
2.Discrete fixed point free surface of hyperbolic isometries.
3.Fundamental groups and covering spaces.

First we know that a torus can be obtained by the following procedure:


Now if we unwrap the torus, we get a "helix tube". We straighten the helix tube, we obtain an infinite cylinder. Then if we unwrap this cylinder again, we get R^2, the Euclidean plane, which is the universal covering space of a torus. The fundamental domain here is the standard square which is tilings the plane R^2.

On the other hand, we can also obtain a torus by gluing a hexagon as follow:


Then if we unwrap this torus twice as before we get its covering space is:


which is also a tiling of R^2 using hexagon as you can imagine. Magically, the fundamental domain of the torus here is the hexagon.

Now to construct surfaces of constant negate curvature, we can use the idea of covering space and the Poincare model for the hyperbolic geometry.

Similarly, if we use the octagon as the fundamental domain to glue a double torus which looks like:


However, there would be a "mass of paper" at the intersections where all the loops meet as you can imagine. To clean the mass, the idea is to give this intersections a lot of negative curvature to fit in all the paper shown as follow:


This uses the Poincare model for the hyperbolic geometry as follow:


This is the universal covering space of the double torus.(This was done by Thurston when he had his oral^_^)


This picture is obtained from the first one by performing a hyperbolic isometry sending the left vertex of the large bottom a to the center of the disk.

If you have time, take a look at this cool video to help you understand!!
part 1: http://www.youtube.com/watch?v=AGLPbSMxSUM
part 2: http://www.youtube.com/watch?v=MKwAS5omW_w&NR=1

Wednesday, June 16, 2010

Wed June 19

Fix a geometry. Define a tile as a convex figure bounded by geodesic arcs.
Problem: Make a list of tiles where each angle is either pi/n or 2pi/n with symmetry.


HOMEWORK:
1. Anand will work out the problem for plane geometry (that is, in R^2).

2. Jingyu will work out the problem for spherical geometry (that is, in the sphere). (The answer is an interesting finite list and a not-so-interesting infinite list)


3. Matt may work out this problem  for hyperbolic geometry LATER

4. Robert: Get a tiling of the plane by hexangons. Consider the group of symmetries with no fixed points. Determine which surface is obtained.

5. Google Russell's paradox. (Wikipedia will be a good source). Read the contents. It will be discussed next week.

6 Jingyu will try to formalize the argument proving that in a simply connected space a tiling will "fit".

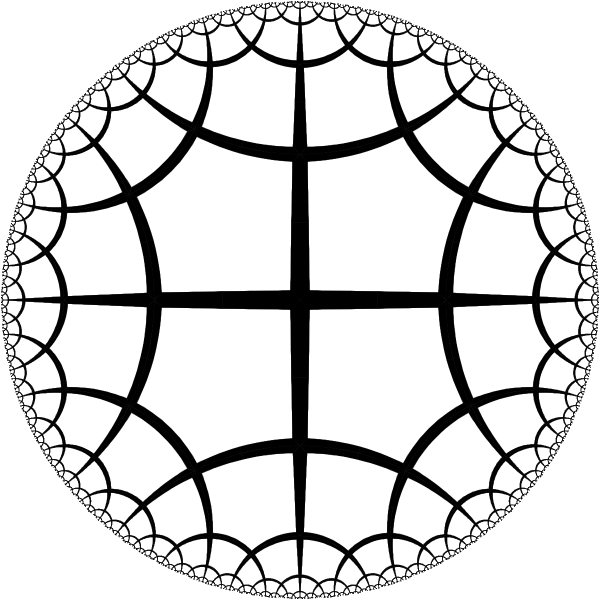
The picture below is a tiling of the Poincare disk by pentagons with right angles.

Wednesday, June 9, 2010

Homework for June 16

What is the number of  surface words  on an alphabet of 2n letters  x1, x2.. xn, X1, X2.. Xn?

Notes from 6/2/10

Thought I'd jot down some of the notes I took from last week's meeting:

We started with some more formal definitions.

Definition: A subset U of Rn is called open if for each element x in U, there exists some n-ball centered at x and contained in U. U is an open set.

Definition: A neighborhood of a point x in Rn is a subset X of Rn such that X contains an open set, U, containing x.

Exercise: The collection of open sets in Rn is:
1. Closed under arbitrary union
2. Closed under finite intersection
3. The null set is open, Rn is open

Any neighborhood X of x is also a neighborhood for all y in V for some open set V which also contains x.

4. Hausdorff Property of Rn: If x is a distinct point from y, then there exist disjoint neighborhoods of x and y.

Fact: A function f which maps Rn to Rm is continuous if and only if fro all x in Rn and any neighborhood V of f(x) in Rm there is a neighborhood, U, of x in Rn so that f(U) (the restriction of the function to the subset U) is a subset of the neighborhood V in Rm.

Definition: A Hausdorff topological space X is a set of points provided with a family of subsets called "open sets" which satisfy properties 1,2,3,4 listed above.

We say two spaces X1 and X2 are homeomorphic if there is a bijection carrying the open sets of X1 to the open sets of X2.

Definition: An n-manifold is a Hausdorff topological space so that each point has a neighborhood homeomorphic to a neighborhood of a point in Rn.

There is a deep result that n is well-defined because of invariance of domain.

Definition: A closed manifold is a manifold that can be covered by finitely many finite neighborhoods.

After these series of definitions, we moved into the problem of classification of surfaces and curves by words.

Given a surface with boundary given by a surface word (which is obtained from constructing the surface by gluing a polygon), there exists a bijection between the free homotopy classes of curves of S and the cyclic reduced words in the alphabet of the surface word.

Let us take our surface word to be aAbB. Some curves are a, aB, AB, etc.

We are also interested in reduced words, which do not have a letter and its associated gluing letter next to each other in any cyclic permutation of the word.

For example, abA is not reduced, since it has a and A next to each other in another cyclic permutation of the word (say Aab).

Definition: A primitive word is a word that is not a power of other words.

We see for instance that the word abab is not a primitive word, as it is (ab)^2.

We can then ask questions about minimal self-intersection. For instance, fixing a particular surface, what are the possible self-intersections of a word of length 1? We then created a small chart characterizing some of the possibilities for curves.

We can ask a series of similar questions. For example, instead of considering just self-intersections, we can take a pair of curves and consider how many total intersections occur.

We also consider the idea of multiwords. Multiwords have a length that is the sum of the length of their component words. For example, some multiwords of length 2 might be:
{ab}, {a,b}, {bA}, {a,a}.

As with other words, we can attempt to classify these multiwords too by self-intersections.

Later on we shifted to a discussion on isometries associated with hyperbolic geometry. We discussed two different models, the Poincare disk model and the upper half-plane model.


Please let me know if anyone has any corrections/things I should re-word to these notes.


Tuesday, June 1, 2010

Notes from First Meeting

Here are some of the things I jotted down from last week's meeting: (Feel free to add/correct things)

Topology

What are some of the motivations for the study of topology?
There are some problems that do not depend upon lengths, angles, etc. but on more basic properties (such as connectedness etc.)
Example: Seven Bridges of Konigsberg problem.

Notion of a "surface"

Division into two broad categories:
I.) Configurations of closed curves and geodesics on surfaces
II.) Self-transformations of surfaces and their effects on curves

Surfaces we study are characterized by whether they are orientable (do not contain Moebius strips), the number of boundary components, and the Euler characteristic.

We wish to find invariants that determine the structure of surfaces.

A minimal surface is one where the mean curvature is zero (the radii of curvature for positive and negative sections sums to zero)

An example in real-life is soap bubbles.

For topology, we consider two surfaces the same if we can construct a continuous bijection from one to the other. This continuous bijection between surfaces is called a homemorphism; the two surfaces are said to be homeomorphic.

Manifolds are surfaces which locally take the appearance of Euclidean space. (Tangency of planes at every point of the manifold.)

We can consider curves on these manifolds. While there are an infinite number of curves up to deformation, we are interested in minimal complexity curves, which minimize intersection points.

We call the number of handles in a surface the genus of the surface. For example, a torus (a donut) has genus 1.

We can consider the behavior of curves upon cutting part of our surface.

So broadly, we will study:
surfaces, closed curves of surfaces, classes of closed curves of surfaces, and minimal intersection/self-intersection

We can transition into geometry by endowing our surfaces with further structure, such as a metric (notion of distance).
By adding a metric, we can discuss geodesics, which are the shortest paths between two points on a manifold. Unlike their counterparts in the plane (lines), geodesics can self-intersect.

We can now consider configurations that minimize self-intersection and the distances based on our metric.

We can use geometric arguments to demonstrate that certain configurations are not realizable as geodesics for a given metric, while others can be realized for the metric. These arguments make use of geometric properties though (such as the curvature of the surface).
We studied a particular example (the pair of pants) that was a hyperbolic surface (negative curvature).

Finally, we discussed a method of constructing bounded surfaces from polygons. We take an n-alphabet and consider a 2n-gon. Each letter of the alphabet must appear once. Furthermore, each letter has an associated term. So the letter, a, also has an associated term, a'. To construct the surface, we glue together each letter with its associated term.
For example, we can have our alphabet be {a,b}. (So n=2.) Depending on how we label the sides of our polygon, we can obtain different shapes. So we could have different "surface words" that yield different surfaces. Some surface words are aba'b' and aa'bb'.

We can also consider a different type of word. Given a surface, characterized by some surface word), we can consider different curves on the surface. We can characterize these curves based upon what sides of the polygon (after it has been glued together) they pass through in what order. We can reduce these words by noting that no letter can appear next to its associated letter: a should never appear next to a' in these reduced words.

Generally, we obtain the following statement:

Every free homotopy class of orientable closed curves on a surface with boundary can be labeled by a unique (up to cyclic permutation) reduced word in the alphabet of the surface word.